

- Stock: In Stock
- Product code: 00-00015306

AgiBot OmniHand 3 Ultra-M with 21 Active Degrees of Freedom
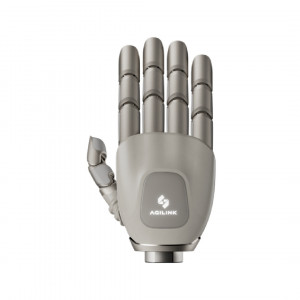
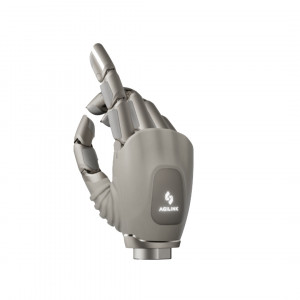
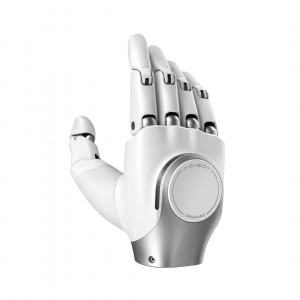
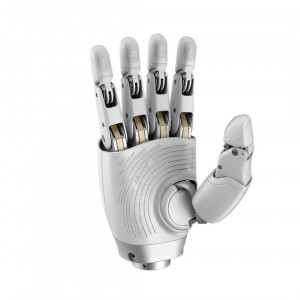
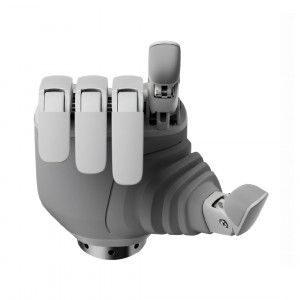
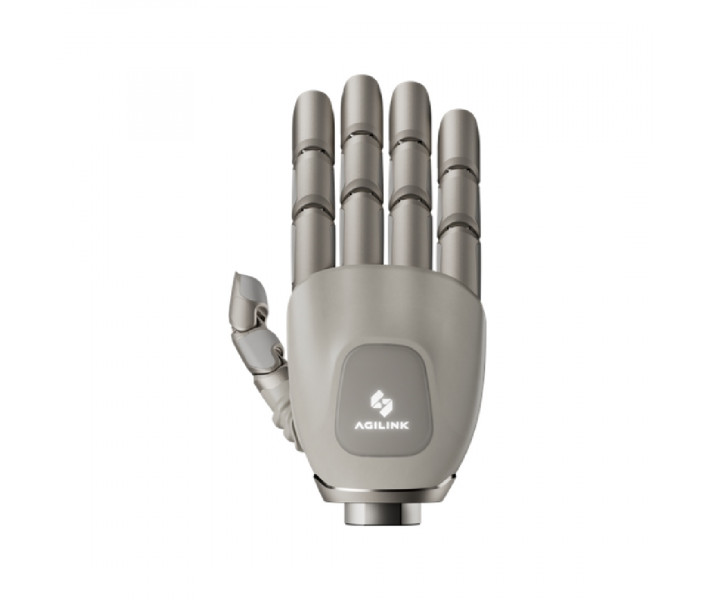
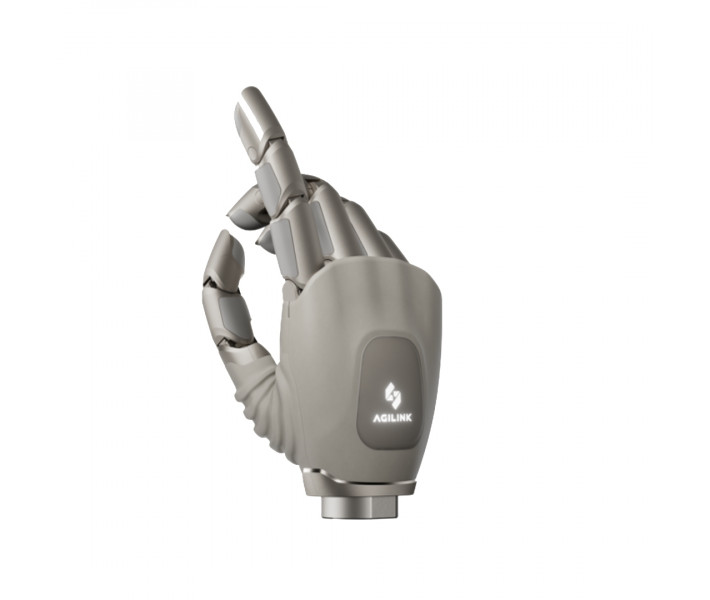
AgiBot OmniHand 3 Ultra-M — is a robotic multi-joint hand for humanoid systems, artificial intelligence research in physical systems, and complex contact manipulations. The model features 21 active degrees of freedom, direct drive for each joint, and tactile sensors on the fingertips and palm. The design is intended for working with physical objects, collecting contact data, and exploring bimanual scenarios.
Main Advantages of AgiBot OmniHand 3 Ultra-M
- 21 active degrees of freedom. The multi-joint design provides a wide range of finger movements and allows precise gripping and holding of objects of various shapes and sizes. The dimensions are close to a human hand, and the force-to-weight ratio is one of the highest in its class.
- Direct joint drive. The drive directly transmits movement to the hand's joints. Encoder data is available in real-time, and positioning repeatability is ±0.2 mm.
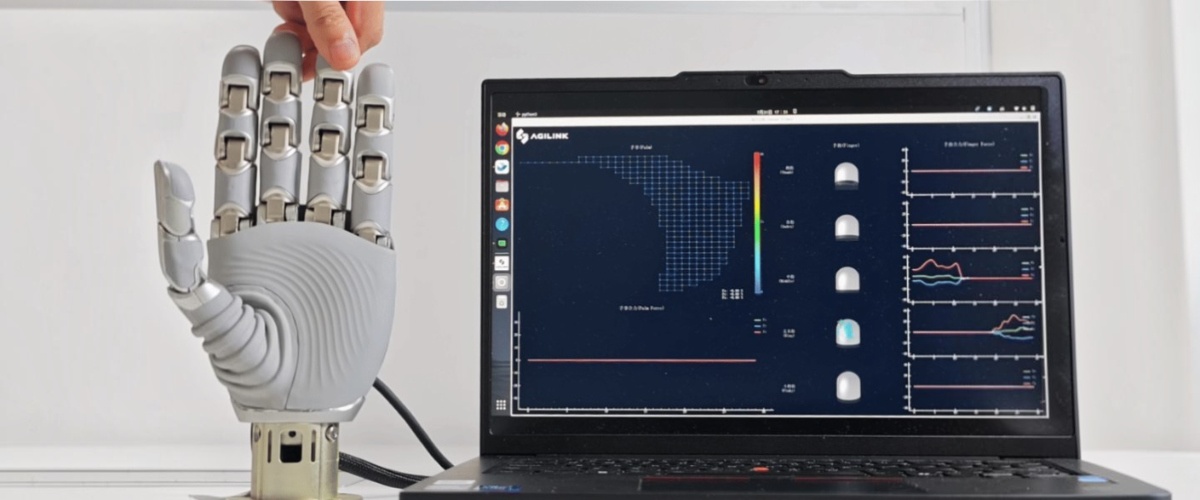
- Tactile sensors on the fingertips. The optical system registers three-dimensional force vectors during contact with an object. The measurement range is 0–30 N, and the deformation accuracy is from 0.08 mm.
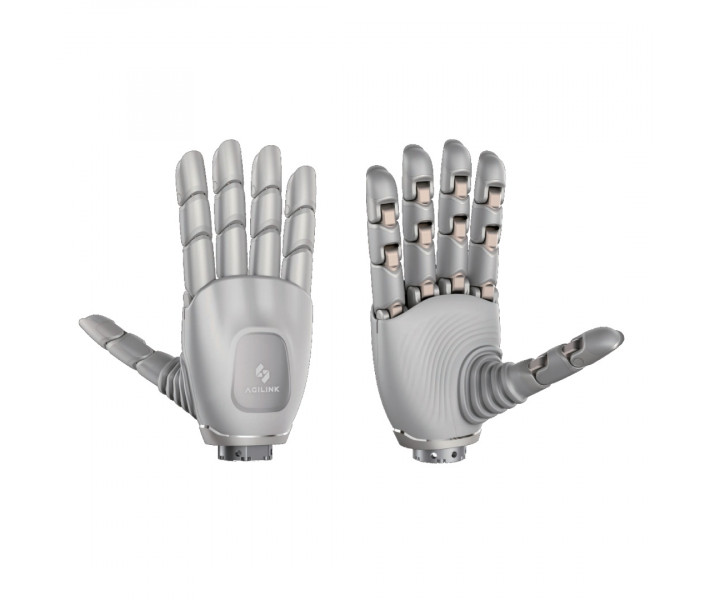
- Three-dimensional tactile sensor in the palm. An additional sensory area registers contact with the inner surface of the hand and complements data from the fingers during complex gripping and holding operations.
- For research and training of robotic systems. The hand is suitable for collecting contact and tactile data, practicing precise manipulations, training embodied artificial intelligence models, and research.
- Operation under prolonged load. During continuous operation, the surface temperature remains within 40–45 °C without degrading performance. The test resource is 500,000 cycles.
- Load up to 5 kg. The hand can work with objects and tools weighing up to 5 kg, expanding the range of available operations for gripping, holding, and moving.
Active Degrees of Freedom and Direct Drive
OmniHand 3 Ultra-M has 21 active degrees of freedom, allowing the robotic hand to independently control the movements of the fingers and joints. Such kinematics enable the reproduction of complex hand positions, the formation of various grip types, and precise manipulations with objects. Each joint is equipped with a direct drive. The position is read by an encoder directly during movement, so the system receives current data on the state of each active joint. Positioning repeatability in the working area is ±0.2 mm. The combination of controlled degrees of freedom, direct drive, and joint position reading is suitable for researching robotic manipulations, grip control, and collecting training data during the physical interaction of the robotic hand with objects.
Tactile Perception of OmniHand 3 Ultra-M
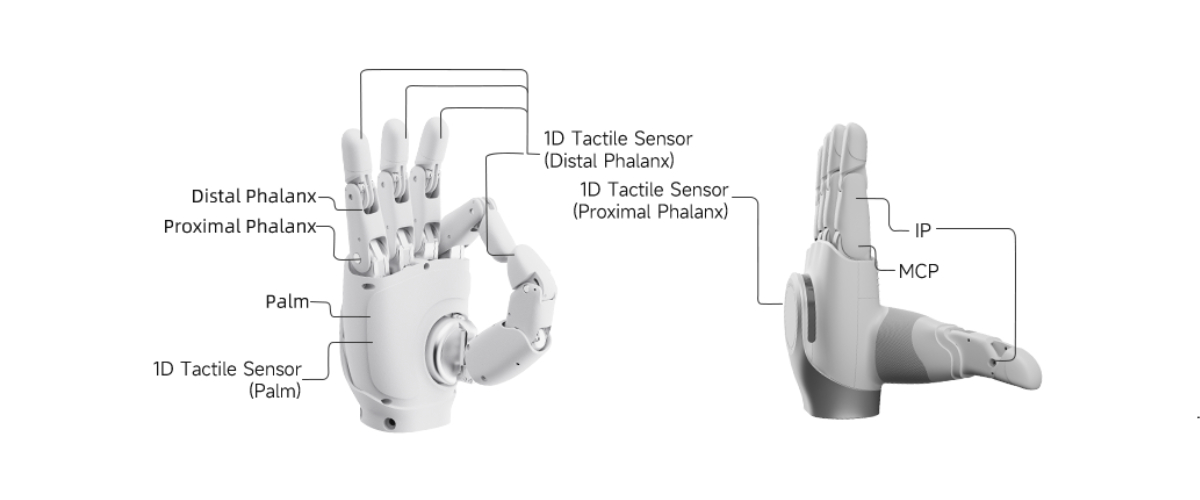
On the fingertips of OmniHand 3 Ultra-M, optical tactile sensors are located. They register contact by the deformation of the sensitive surface and determine the direction and magnitude of mechanical load in three dimensions. The measurement range is 0–30 N, and the deformation accuracy is 0.08 mm. The sensors recognize contact and sliding, as well as interaction with the edge or surface of an object. A separate three-dimensional tactile sensor is installed in the palm. It registers contact in cases where the object touches not only the fingers but also the inner surface of the robotic hand. This provides additional data during holding, moving, and changing the position of the object. The tactile system of OmniHand 3 Ultra-M allows considering the position of the fingers and the nature of contact with the object. It is suitable for precise gripping, inserting components, transferring objects between manipulators, and other operations where contact control is important.
Load and Design
OmniHand 3 Ultra-M has dimensions close to a human hand. The model's dimensions are 189.5 × 88.5 × 40 mm, and the weight is 630 g. These parameters allow the installation of the robotic hand on humanoid robotic platforms and manipulators of the appropriate size. The permissible payload is up to 5 kg. This value should be considered when working with objects, parts, and tools of varying mass. The ratio of size, weight, and mobility of the hand is suitable for robotic systems where precise manipulations and compliance with human hand parameters are important.
OmniHand 3 Ultra-M for Training and Data Collection
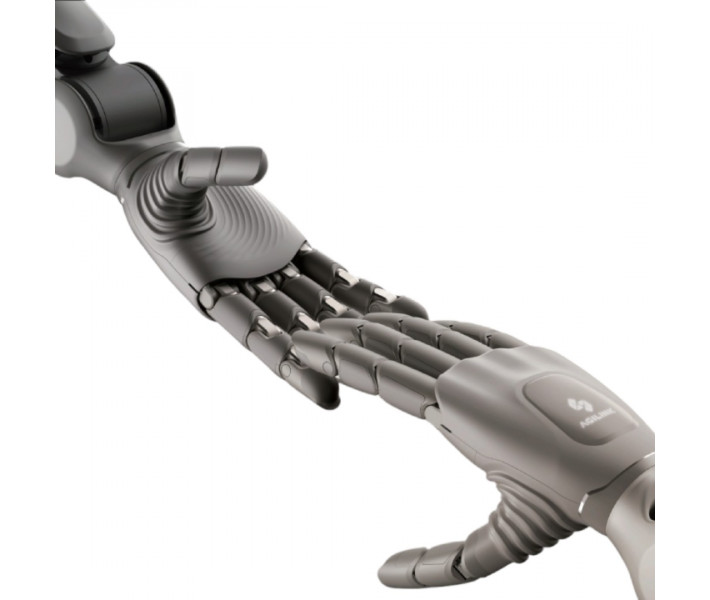
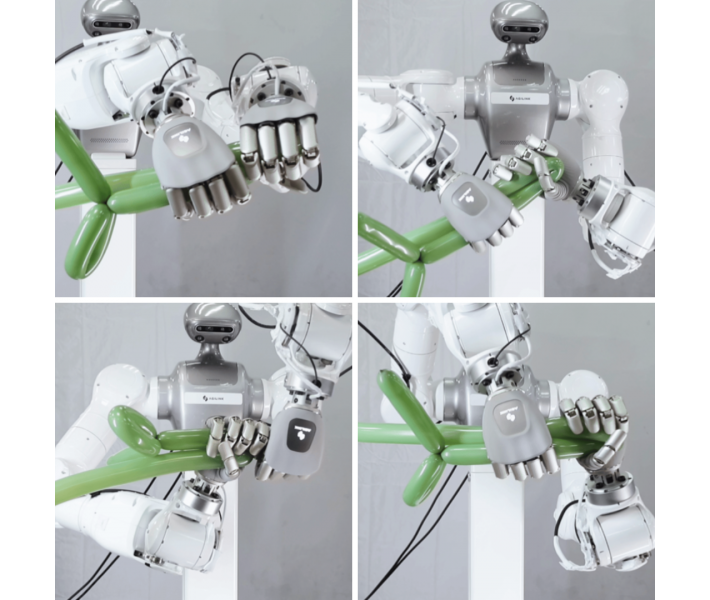
OmniHand 3 Ultra-M is suitable for training robotic systems based on data obtained during physical interaction with objects. The hand registers joint movements, their positions, and tactile contact, allowing the analysis of manipulation execution in real conditions. Tactile sensors on the fingers transmit data on load and deformation during contact, and encoders record the positions of active joints. Such information is needed for training robots to grip, hold, move, and transfer objects. OmniHand 3 Ultra-M is also suitable for researching complex contact operations and working with two robotic hands. Two manipulators can work in coordination with one object or perform related actions. The hand can be used for remote robot control, recording operator demonstrations, forming training data sets, and transferring algorithms developed in a virtual model to a physical robot.
Compatibility with AGIBOT Robotic Platforms
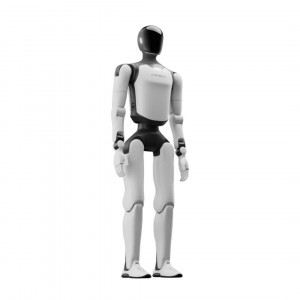
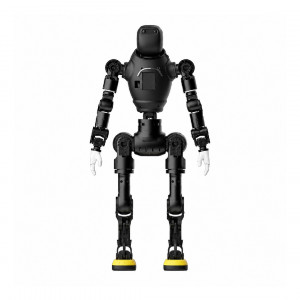
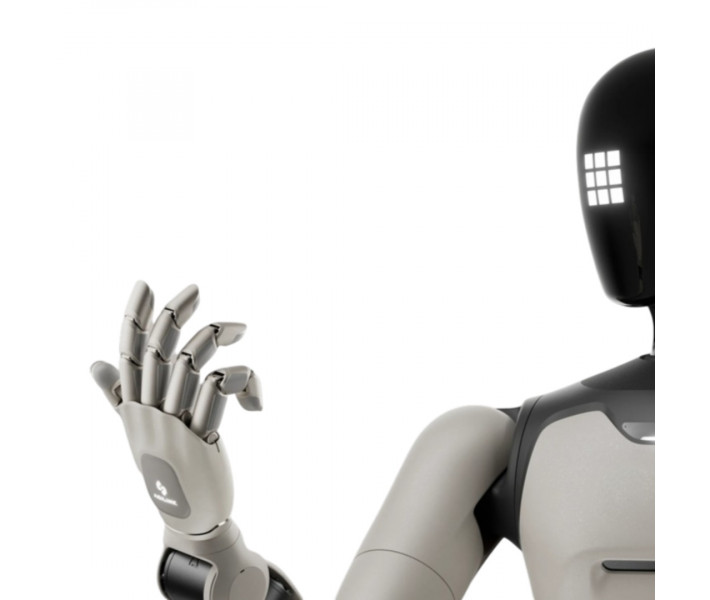
OmniHand 3 Ultra-M is recommended for robots of the AGIBOT A3 series. This configuration is suitable for dual-arm robotic systems, contact manipulation research, and training robots based on data obtained during physical interaction with objects.
For the A2, G2, and X2 series, other models of OmniHand robotic hands or OmniPicker grippers are provided. Therefore, the possibility of installing OmniHand 3 Ultra-M on these platforms should be checked separately, considering the design, connection, and configuration of the specific robot. OmniHand 3 Ultra-M supports CAN FD and Ethernet for data exchange and connection to the robotic system. The compatibility of software control depends on the platform configuration and its software.
Applications of the Robotic Hand
AgiBot OmniHand 3 Ultra-M is suitable for tasks requiring precise gripping, manipulation, and interaction with objects of various shapes and sizes.
- Training robotic systems. Collecting data on movements, joint positions, and contact with physical objects.
- Working with two robotic hands. Performing coordinated operations with objects considering contact data.
- Remote control. Transmitting operator movements to the robotic system and recording performed actions.
- Collecting training data. Recording movements, joint positions, and contact interaction for further robot training.
- Laboratory automation. Working with equipment, laboratory glassware, samples, and other objects.
- Sorting and moving. Gripping, transferring, distributing, and placing objects of various shapes.
- Assembly operations. Installing components, connecting parts, and performing other precise contact actions.
- Working with tools. Gripping and using tools and devices during research and technical operations.
Technical Specifications of AgiBot OmniHand 3 Ultra-M
| Parameter | Value |
| Number of active degrees of freedom | 21 |
| Drive type | Direct drive |
| Load | 5 kg |
| Opening / closing time | 0.3 s |
| Positioning repeatability | ±0.2 mm |
| Interfaces | CANFD, Ethernet |
| Palm tactile sensor | Three-dimensional tactile sensor |
| Palm sensor force measurement resolution | 0.1 N |
| Number of tactile points in the palm | 300 |
| Fingertip tactile sensor | Optical tactile sensor |
| Finger sensor force measurement range | 0–30 N |
| Finger sensor force measurement resolution | 0.005 N |
| Spatial resolution | 0.04 mm |
| Deformation determination accuracy | 0.08 mm |
| Net dimensions | 189.5 × 88.5 × 40 mm |
| Net weight | 0.630 kg |
Order AgiBot OmniHand 3 Ultra-M
AgiBot OmniHand 3 Ultra-M is suitable for research centers, universities, laboratories, robotics developers, and system integrators who need a robotic hand for precise manipulations, tactile data collection, working with objects, and training robotic systems. Our specialists will help select the configuration, check compatibility with the robotic platform, clarify connection options, configuration, and delivery conditions.