

- Stock: In Stock
- Product code: 00-00015309

AgiBot OmniHand 3 for Humanoid and Mobile Robotic Platforms
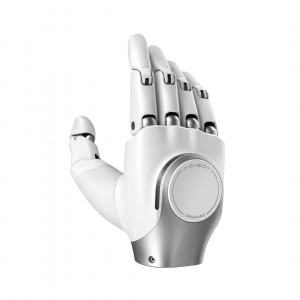
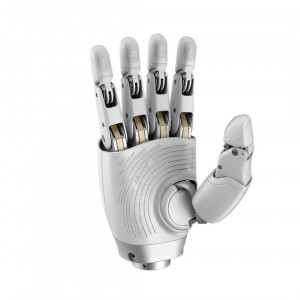
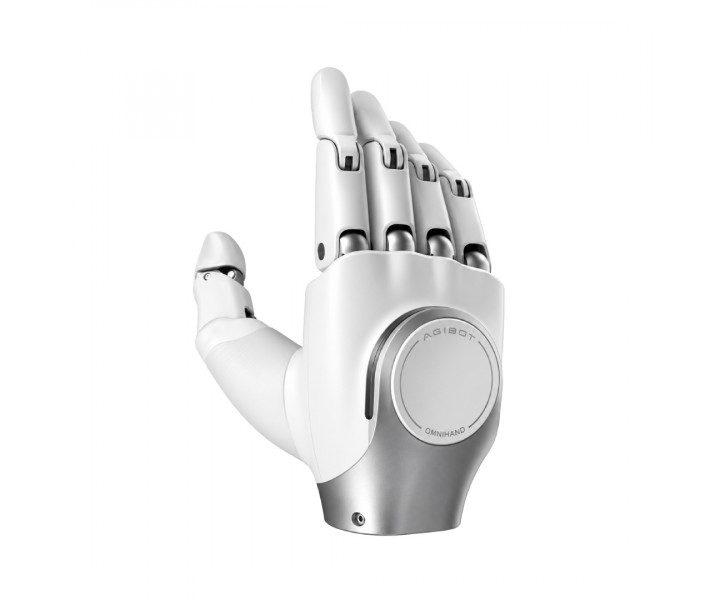
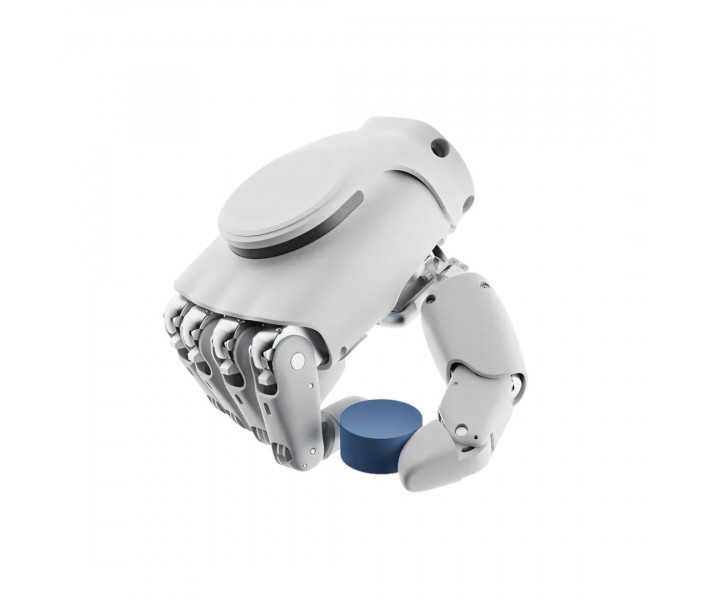
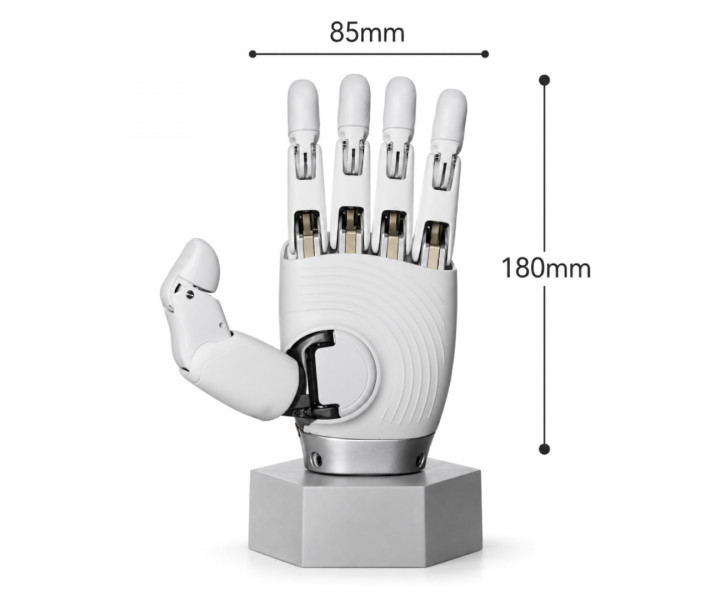
AgiBot OmniHand 3 is a robotic hand for humanoid robots, mobile manipulators, and service platforms. It features 10 active and 6 passive degrees of freedom, allowing for finger movements, object gripping, and gesture reproduction. The hand weighs 510 g. The tactile system includes over 300 sensitive points located on the fingers, palm, and back of the hand. They register contact with objects during gripping, holding, and other manipulations. OmniHand 3 is suitable for working with objects of various shapes, reproducing gestures, and exploring human-robot interaction.
Main Advantages of AgiBot OmniHand 3
- Flexible finger movement control. The hand has 10 active and 6 passive degrees of freedom, allowing for various finger positions, gesture execution, and working with objects of different shapes.
- Handling objects weighing up to 5 kg. The allowable load is up to 5 kg, enabling the gripping, holding, and moving of objects within this range.
- Low load on the robotic arm. The hand weighs 510 g, making it suitable for installation on humanoid robotic platforms and mobile manipulators.
- Touch control on different parts of the hand. Over 300 load-sensitive elements are located on the fingertips, palm, and back of the hand, registering contact with a human or object.
- Contact recognition across the entire hand surface. Tactile data is received simultaneously from multiple areas, allowing for contact consideration not only with the fingers but also with the palm and back of the hand.
- Quick hand opening and closing. The typical time for full opening or closing is 0.5 s, suitable for operations involving repetitive gripping and moving of objects.
- Connection to robotic platforms. Interfaces CAN FD and RS485 are provided for data exchange, used for transmitting commands and data between the hand and the robot's control system.
Movable Kinematics with Active and Passive Joints
OmniHand 3 has 10 active and 6 passive degrees of freedom. A degree of freedom defines a separate movement in the mechanical design of the hand. Active degrees of freedom are controlled by drives and execute control system commands. Passive ones move according to joint design and mechanical interaction during hand operation. This structure allows for forming various finger positions, performing typical gestures, and applying multiple object gripping methods. The hand can adjust finger positions to the object's shape within the available kinematics.
Distributed Tactile System of OmniHand 3
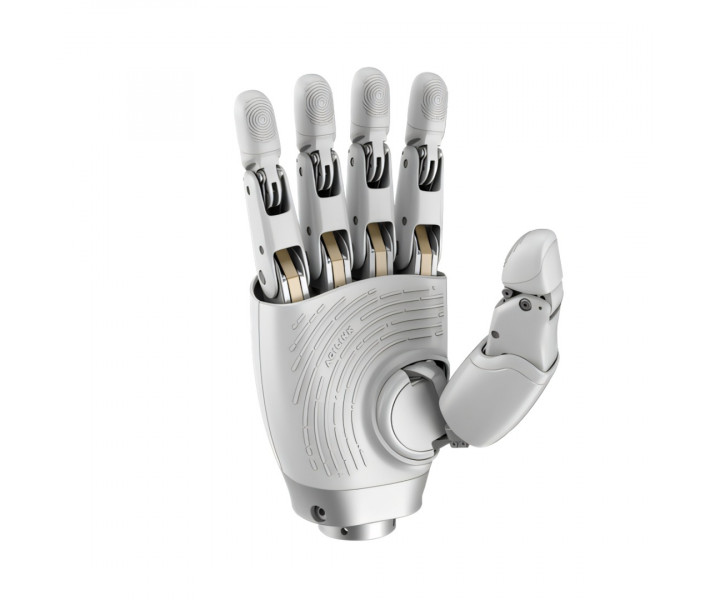
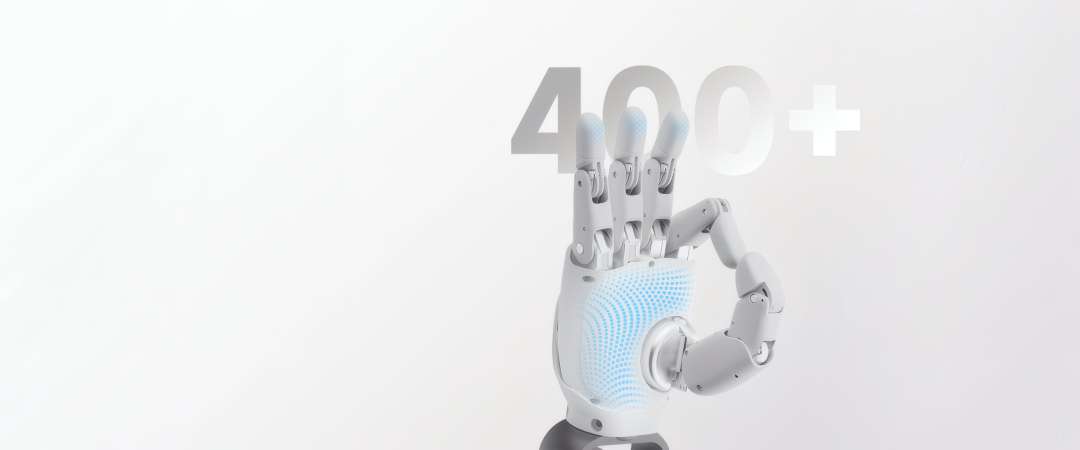
OmniHand 3 is equipped with over 300 tactile elements distributed across the main contact zones of the hand. They record mechanical contact with objects or humans and transmit data about the touch location during gripping, holding, and other manipulations:
- fingertips;
- palm;
- back of the hand.
This arrangement allows determining where contact occurs during object gripping or human interaction. The system receives data not only about finger positions but also about direct physical contact with an external object. The tactile system operates on a one-dimensional measurement principle and has a resolution of 0.1.
A separate sensor zone on the back of the hand allows registering touch beyond the fingers and palm. This expands the capabilities of OmniHand 3 in tasks involving human-robot interaction.
Object Gripping and Working with Loads up to 5 kg
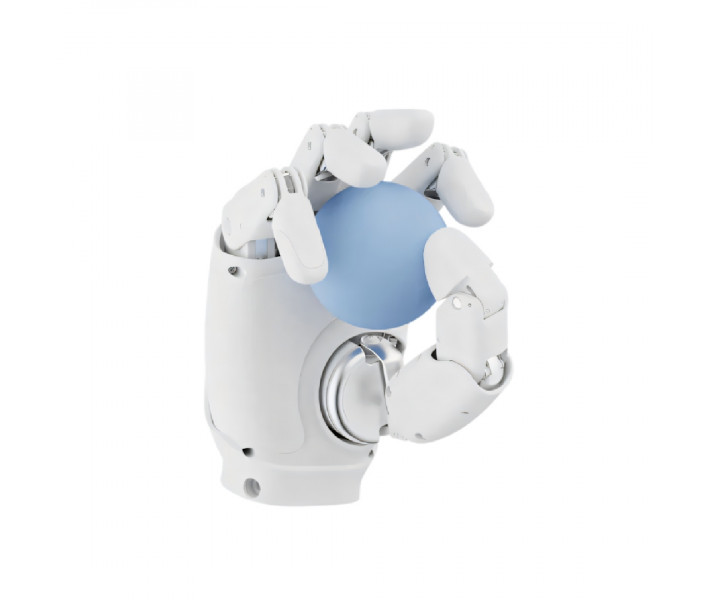
AgiBot OmniHand 3 is designed to work with loads up to 5 kg. This indicator defines the allowable weight of objects during hand operation and is not a measure of finger gripping force or the effort of a separate drive. The hand's design allows working with objects of various shapes and sizes, adjusting finger positions according to the object's geometry. This is suitable for gripping, holding, moving, and transferring objects in robotic systems.
Tactile Interaction with Humans and Objects
OmniHand 3 registers physical contact with a human or object in different zones of the hand. Touch data is transmitted to the control system and can be considered during gripping, holding, and other contact operations.
Sensor zones on the fingers, palm, and back of the hand allow determining contact at multiple points. This is useful during interactions where the robot's movement should depend on actual touch with an object or human. The design also includes pinch protection, helping make contact with humans and objects more controlled during robotic system operation.
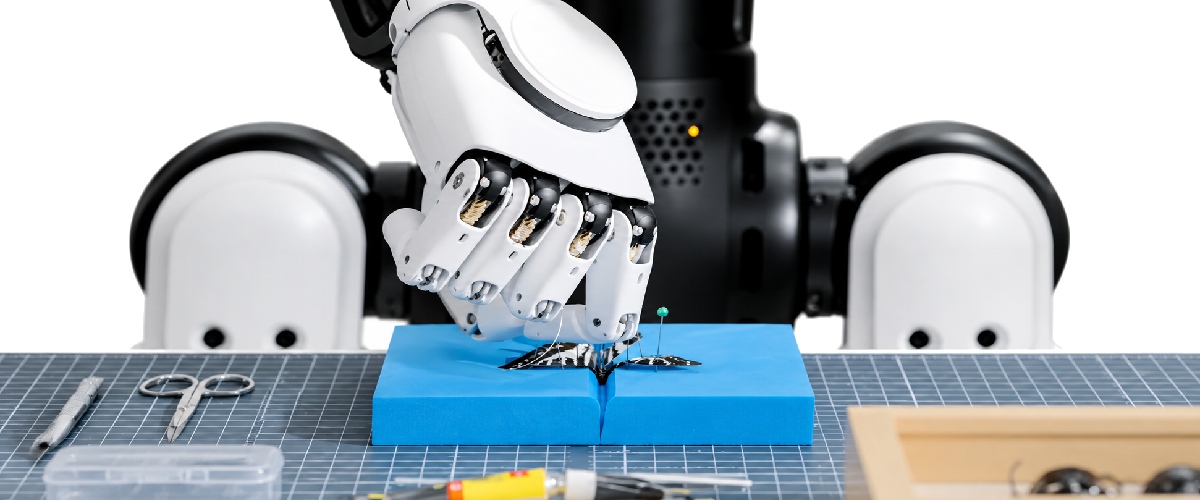
Applications of AgiBot OmniHand 3
- Education and training programs. Used in universities, laboratories, and research centers for studying robotics, kinematics, motion control, and tactile systems.
- Human-robot interaction. Research on physical contact, robotic system response to touch, and the use of tactile data during control.
- Mobile robotics. Installation on mobile manipulators for gripping, holding, moving objects, and performing other operations with a robotic hand.
- Service robots. Working with objects, performing gestures, and contact interaction in robotic systems designed for auxiliary and service tasks.
- Research robotic platforms. Used as an end-effector module for testing control algorithms, object gripping, and tactile interaction.
Compatibility with Robotic Platforms
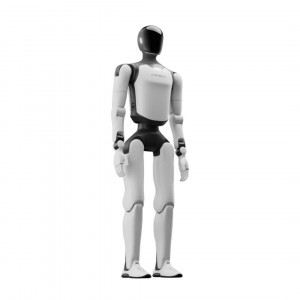
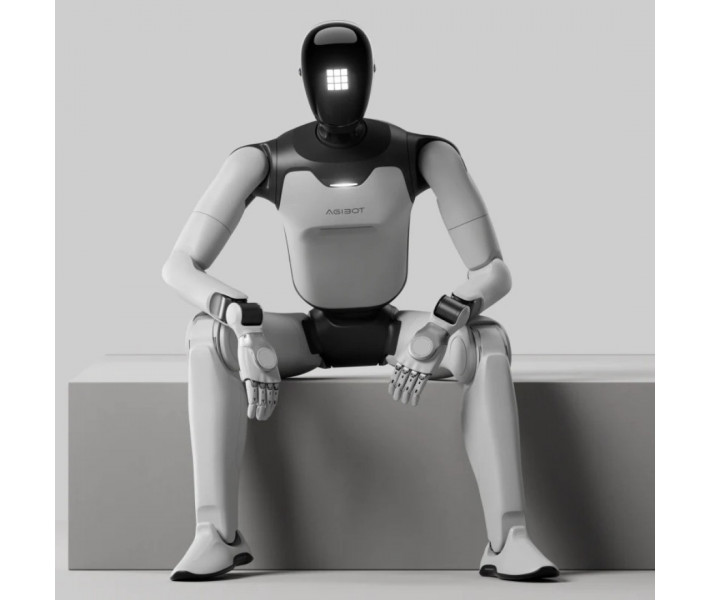
OmniHand 3 is suitable for installation on humanoid robotic platforms and mobile manipulators. Before connecting, it is necessary to check the mechanical, electrical, and software compatibility of the hand with a specific robot model.
Interfaces CAN FD and RS485 are provided for data exchange. When selecting a configuration, it is also necessary to consider the type of mounting, controller requirements, power supply, and software control.
Package Contents of AgiBot OmniHand 3
The AgiBot OmniHand 3 package includes the main components for connecting the hand to a robotic system and data transmission. The supply also includes cables for power, communication, and service connection, as well as a compliance document.
- Robotic hand OmniHand. Main actuator module for installation on a robotic arm or mobile manipulator.
- RS485 communication cable. Used for data exchange between the hand and the control system via the RS485 interface.
- CAN FD communication cable. Designed for connecting OmniHand to a compatible controller or robotic platform via CAN FD.
- Power cable. Provides connection of the hand to a power source according to system requirements.
- USB Type-C data cable. Used for device connection during setup, data exchange, or service operations.
- Certificate of compliance. A document included in the supply package confirming the product's compliance with established requirements.
Note: The exact composition of the AgiBot OmniHand 3 supply package should be clarified before placing an order.
Technical Specifications of AgiBot OmniHand 3
| Parameter | Value |
| Degrees of freedom | 10 active + 6 passive |
| Total number of degrees of freedom | 16 |
| Maximum load | 5 kg |
| Opening/closing time | 0.5 s |
| Positioning repeatability | ±0.3 mm |
| Type of tactile sensor | One-dimensional |
| Number of tactile elements | Over 300 |
| Sensor resolution | 0.1 |
| Communication interfaces | CAN FD, RS485 |
| Tactile system | 1D sensor |
| Remote control system | Dex-UMI |
| Software environment | ROS 2 |
| Development tools | Python, C++ |
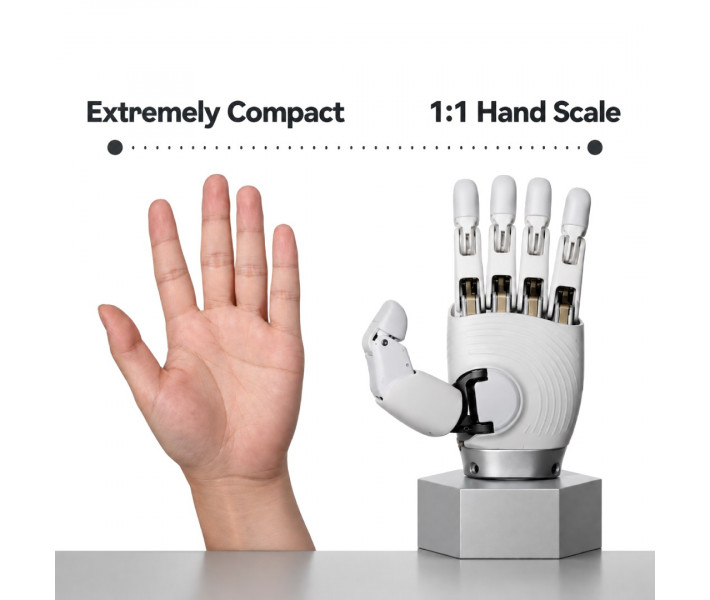
| Net dimensions | 180 × 85 × 38.5 mm |
| Net weight | 0.510 kg |
Order AgiBot OmniHand 3
AgiBot OmniHand 3 is suitable for research centers, universities, robotics developers, system integrators, and enterprises needing a robotic hand for working with objects, gesture reproduction, tactile interaction, and installation on humanoid robots or mobile manipulators. Our specialists will help select the configuration, check compatibility with the robotic platform, clarify connection and software control options, and agree on the package and delivery conditions.