

- Stock: In Stock
- Product code: 00-00015305

Lightweight Robotic Hand for Humanoid and Mobile Platforms
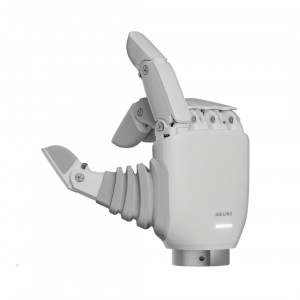
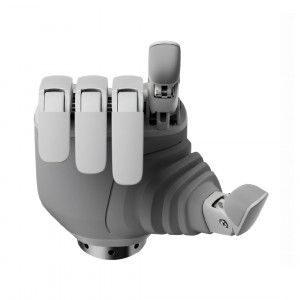
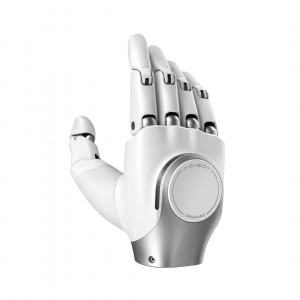
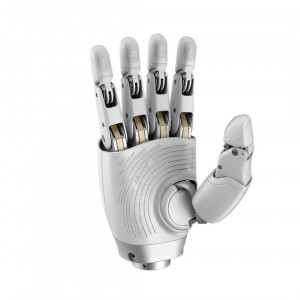
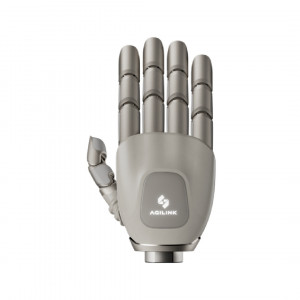
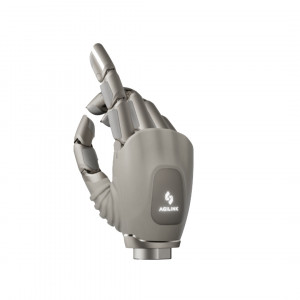
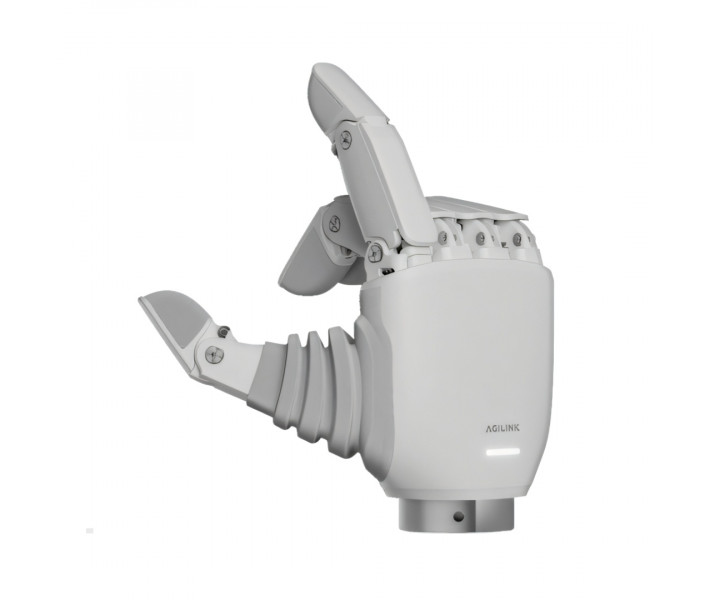
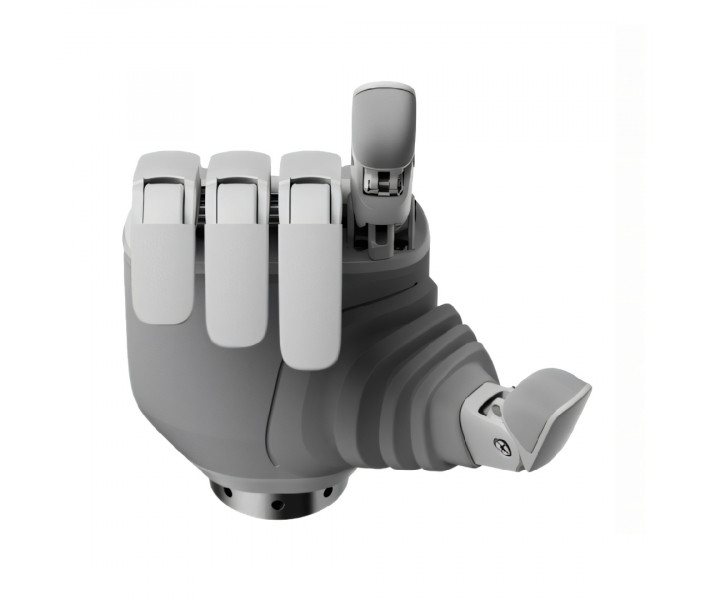
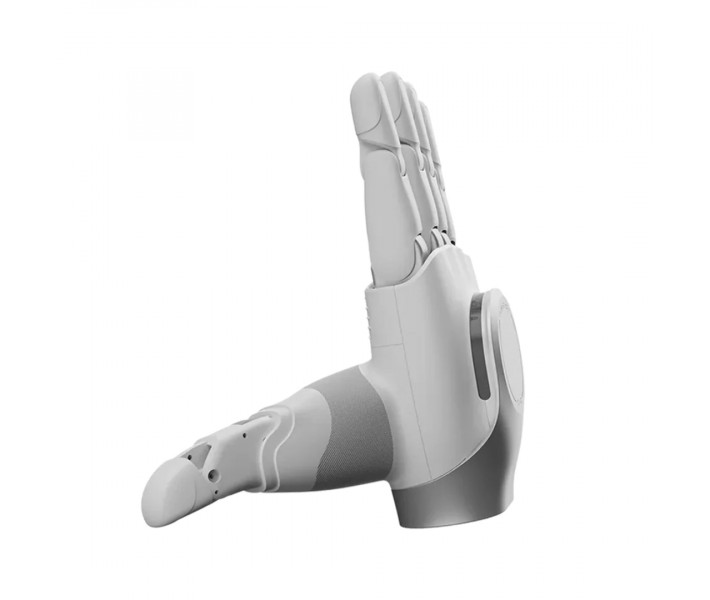
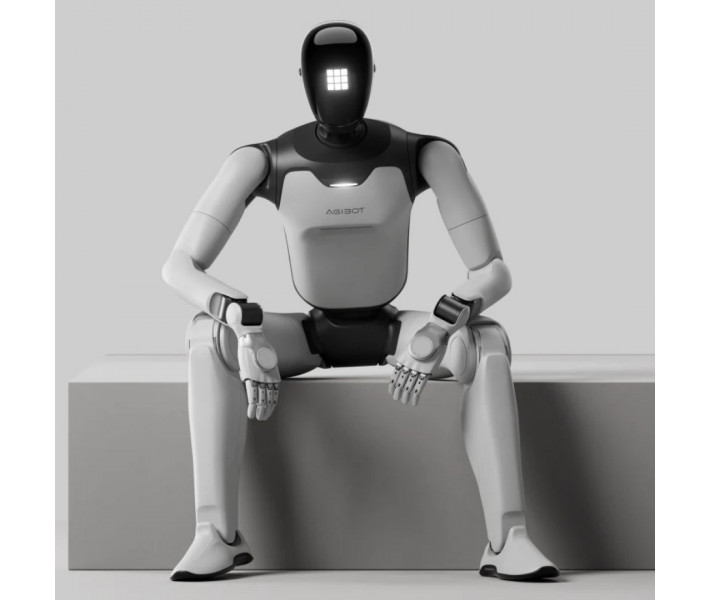
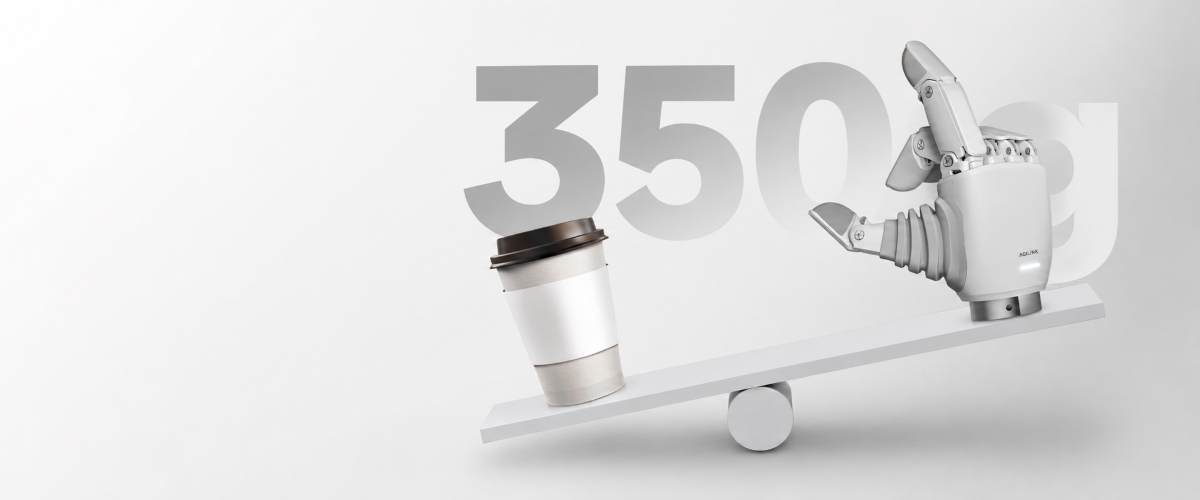
AgiBot OmniHand 3 Lite is a compact robotic hand for small-format robots, mobile manipulators, and service platforms. The model features 4 active and 7 passive degrees of freedom, a tactile sensor, and is designed for loads up to 1 kg. Its small size and weight of 350 g allow the OmniHand 3 Lite to be installed on compact robotic arms where reducing the load on the end part of the manipulator is important.
Main Advantages of AgiBot OmniHand 3 Lite
- Minimal load on the robotic arm. The weight of the OmniHand 3 Lite is 350 g, making it suitable for compact humanoid robots, mobile manipulators, and service platforms.
- Flexible finger kinematics. The hand has 4 active and 7 passive degrees of freedom, allowing for controlled movements and adapting finger positions during contact with objects.
- Load handling. The permissible payload is 1 kg, determining the weight of objects the hand can work with within the specified modes.
- Durability and protective coating. The metal construction is complemented by a solid silicone layer that protects the external elements of the hand during contact and mechanical loads.
- Compatibility with Dex-UMI. The OmniHand 3 Lite can be used in remote control and motion capture systems for research, robot training, and control algorithm testing.
- Development and training opportunities. An open set of software tools allows for creating and testing custom algorithms, conducting laboratory work, and developing experimental robotic systems. A wrist camera is available as an additional accessory.
Movable Kinematics with Active and Passive Joints
OmniHand 3 Lite has 4 active and 7 passive degrees of freedom. The degree of freedom defines a separate movement that the mechanical construction of the hand can perform or allow. Active degrees of freedom are controlled by drives and execute commands from the control system. Passive ones move according to the joint design, finger positions, and contact with an object. This helps the hand adapt finger positions during the gripping and holding of objects of various shapes.
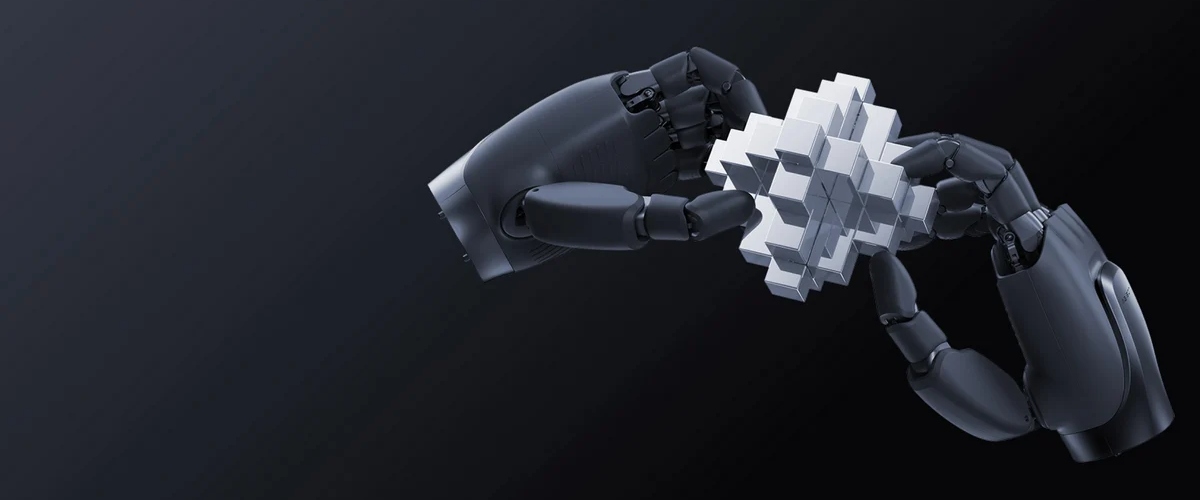
Metal Frame and Silicone Coating
OmniHand 3 Lite is built on a high-strength metal frame, forming a rigid base for the robotic hand and designed for mechanical loads during active movements. The external part of the hand has a solid silicone coating, creating a single contact surface and protecting the internal elements of the construction during interaction with objects. The construction has passed impact, drop, and collision tests.
Tactile Sensor of OmniHand 3 Lite
OmniHand 3 Lite is equipped with a one-dimensional tactile sensor, which registers contact during the hand's interaction with objects. The sensor resolution is 0.1. The tactile sensor complements the data on finger positions with information about direct touch to the object. This allows considering the moment of contact during gripping, holding, and moving objects.
This type of sensor is suitable for tasks where it is important to control the physical interaction between the hand and the object. The obtained data can be used by the robot's control system during repetitive manipulations and work with objects of various shapes.
Open Toolkit for Developers
OmniHand 3 Lite supports an open set of tools for development and experimental tasks with robotic systems. This allows using the hand in educational projects, laboratory stands, and custom developments.
The toolkit is suitable for rapid prototyping, setting up control algorithms, and testing robotic scenarios. This approach is convenient for universities, research laboratories, and teams developing their own robotic solutions.
Hand Movement Speed
The typical time for opening or closing the OmniHand 3 Lite is 0.5 s. This indicator allows assessing the speed of the main hand movement during gripping, releasing, and repetitive work with objects.
The value of 0.5 s is a typical working indicator, not a guaranteed maximum time for each cycle. The actual speed may depend on the operating mode, load, and settings of the robotic system.
Applications of AgiBot OmniHand 3 Lite
- Service robotics. OmniHand 3 Lite is suitable for service robots where the hand is used as the end module of the manipulator for working with objects and performing auxiliary operations.
- Mobile manipulators. The hand can be installed on mobile robotic platforms with a manipulator. When selecting a configuration, it is necessary to consider the type of mounting, weight, dimensions, permissible load, and interface compatibility.
- Educational platforms. OmniHand 3 Lite is suitable for universities, laboratories, and training centers where robotics, manipulator control, and interaction with objects are studied.
- Prototyping robotic systems. An open set of development tools allows creating and testing custom control algorithms, setting up experimental stands, and testing new work scenarios.
Technical Specifications of AgiBot OmniHand 3 Lite
| Parameter | Value |
| Degrees of Freedom | 4 active + 7 passive |
| Payload | 1 kg |
| Typical Opening/Closing Time | 0.5 s |
| Positioning Repeatability | ±0.5 mm |
| Tactile Sensor | One-dimensional |
| Sensor Resolution | 0.1 |
| Communication Interfaces | CAN FD, RS485 |
| Control System Compatibility | Dex-UMI |
| Software Environment | ROS 2 |
| Development Tools | Open set of tools |
| Frame Material | Aerospace-grade metal frame |
| External Coating | Solid silicone coating |
| Net Dimensions | 140 × 70 × 32 mm |
| Net Weight | 0.350 kg |
Order AgiBot OmniHand 3 Lite
AgiBot OmniHand 3 Lite is suitable for universities, research laboratories, robotics developers, system integrators, and companies needing a compact robotic hand for small-format humanoid robots, mobile manipulators, and service platforms. Our specialists will help verify compatibility with the robotic system, select the configuration, clarify connection options, software control, and the availability of an additional wrist camera.