

- Stock: In Stock
- Product code: 00-00015307

Industrial Gripper for Humanoid and Mobile Platforms
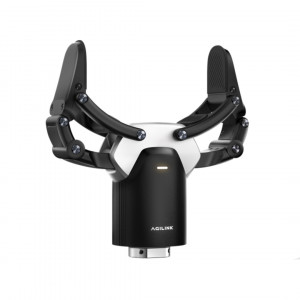
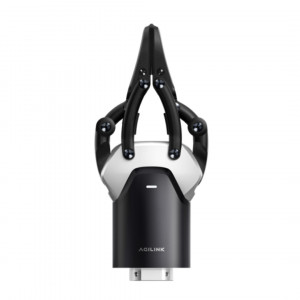
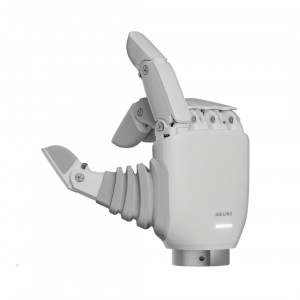
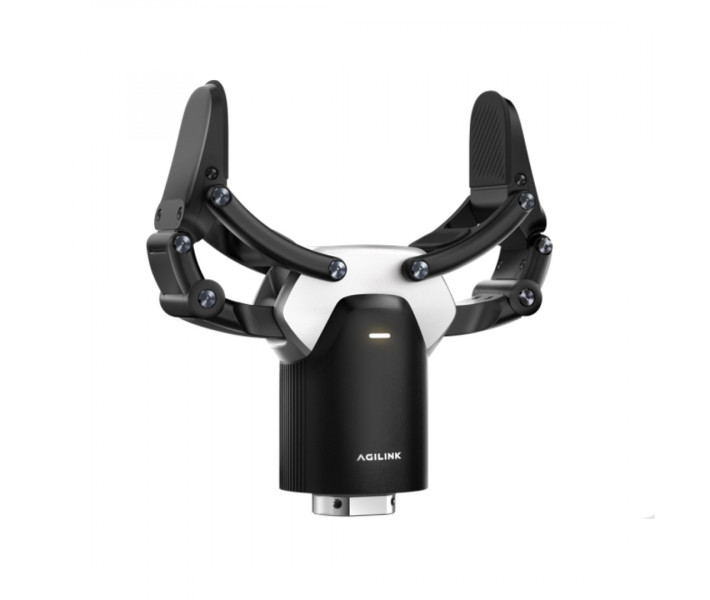
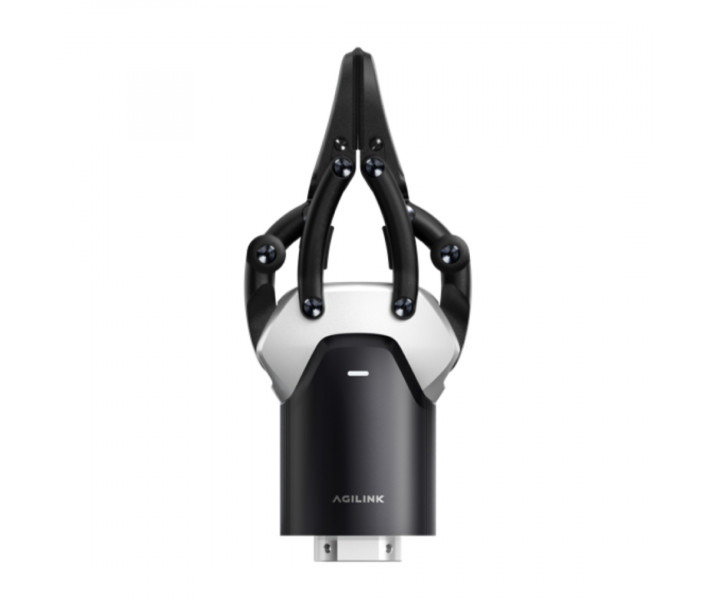
AgiBot OmniPicker 3 — a robotic gripper for sorting, logistics, automated item movement, and data collection for training robotic systems. The model has a maximum force of up to 140 N and a load capacity of up to 5 kg. The tactile system measures contact force with a resolution of 0.1 N, allowing control over the gripper's interaction with the item. Adaptive control helps work with objects of different shapes, adjust the grip, and perform operations with items requiring precise control.
Main Advantages of AgiBot OmniPicker 3
- Controlled grip with high force. The maximum gripping force is 140 N, and the design has been tested for 1,000,000 cycles at full load. This allows the gripper to be used in repetitive operations with high resource demands.
- Payload up to 5 kg. The gripper is designed to work with items of this weight during holding and moving.
- Contact force measurement. The tactile sensor registers the load in the contact area and transmits this data to the control system. The measurement resolution is 0.1 N.
- Precise repetition of the set position. Positioning repeatability is ±0.1 mm, which is important for sorting, moving, and other operations with repetitive movements.
- Connection to the robot control system. Interfaces CAN FD and RS485 are provided for transmitting commands and data, allowing OmniPicker 3 to be connected to compatible robotic platforms and controllers.
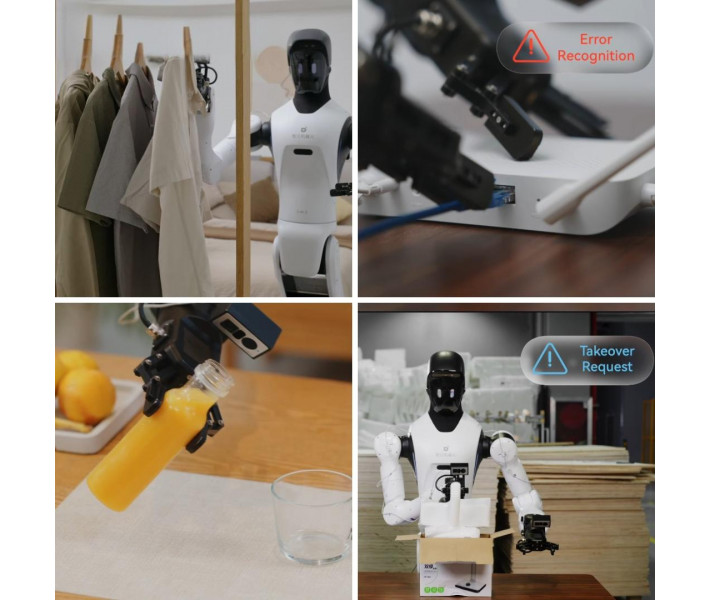
- Data collection during work with items. OmniPicker 3 can be used to record data on gripping, contact, and object movement during the training of robotic systems. It supports working with Dex-UMI, and cameras can be connected as additional equipment.
Gripping and Positioning of OmniPicker 3
OmniPicker 3 develops a gripping force of up to 140 N and is designed for a payload of up to 5 kg. The actual reliability of holding depends on the shape, material, contact surface, item position, and the nature of the robotic system's movement. Therefore, the values 140 N and 5 kg should be evaluated considering the specific operation.
The maximum stroke of the gripping mechanism is 110 ± 5 mm, which determines the available range of movement of its working elements. The suitability for a specific item depends not only on its dimensions but also on its geometry and gripping method. Positioning repeatability is ±0.1 mm. This parameter characterizes the mechanism's ability to repeatedly return to a set position and is significant for sorting, moving parts, and repetitive automated operations.
Adaptive Gripping with Contact Force Control
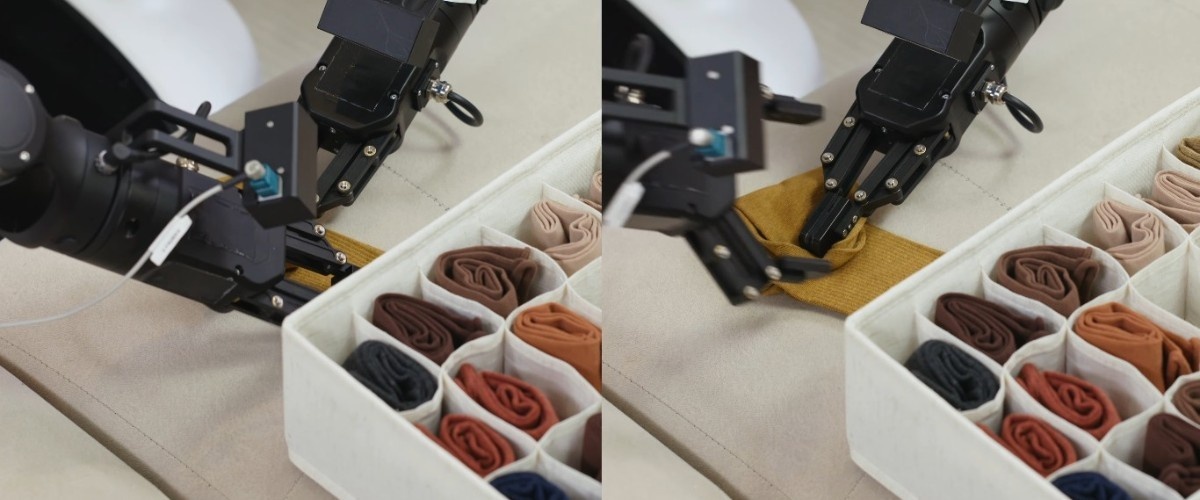
OmniPicker 3 controls the mechanical impact on the item based on data from the tactile sensor. The sensor on the working surface registers the contact force and transmits these indicators to the control system in real-time. Based on the received data, the system can adjust the force according to the shape, material, and position of the item. This is useful when working with irregularly shaped parts, fragile items, and objects that require precise contact control. The operating parameters are adjusted according to the specific item and operation. It is necessary to consider the geometry of the part, material properties, contact area, and movement conditions.
Tactile Sensor with Resolution
OmniPicker 3 is equipped with a one-dimensional tactile sensor that measures contact force on the gripper's working surface. The measurement resolution is 0.1 N, allowing the detection of small changes in load during contact with the item. The obtained data is transmitted to the control system and can be considered during holding, moving, and working with objects sensitive to excessive mechanical impact.
OmniPicker 3 for Data Collection and System Training
OmniPicker 3 is suitable for data collection during physical manipulations with items. The gripper can transmit information about performed actions and contact force, and when additional cameras are connected, visual information can be added to the data set. The model is also compatible with UMI, allowing it to be used in systems for recording manipulation data for further robot training. Suitable for research stands, teleoperation scenarios, and preparing training data sets.
OmniPicker 3 serves as a hardware module for information collection and physical work with objects. The actual process of model training takes place separately in the software and computational part of the robotic system. Connection parameters to UMI, data exchange structure, and additional configuration requirements should be checked for the specific robotic platform.
Industrial Sorting and Logistics
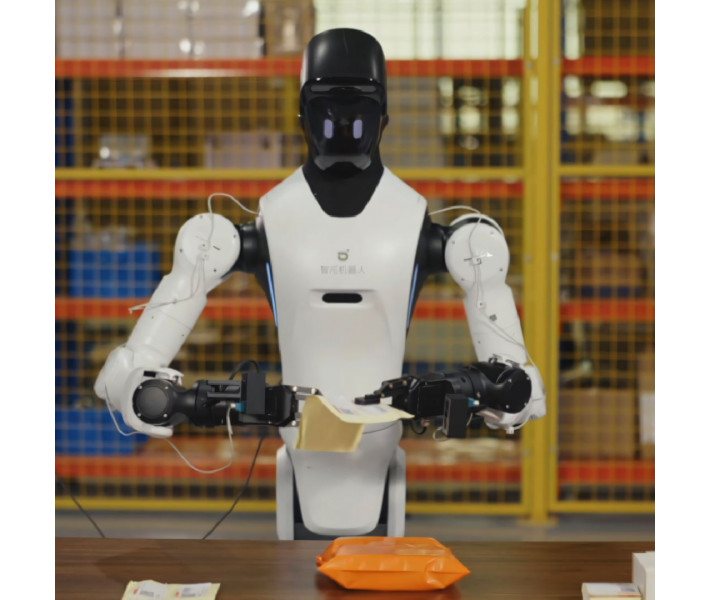
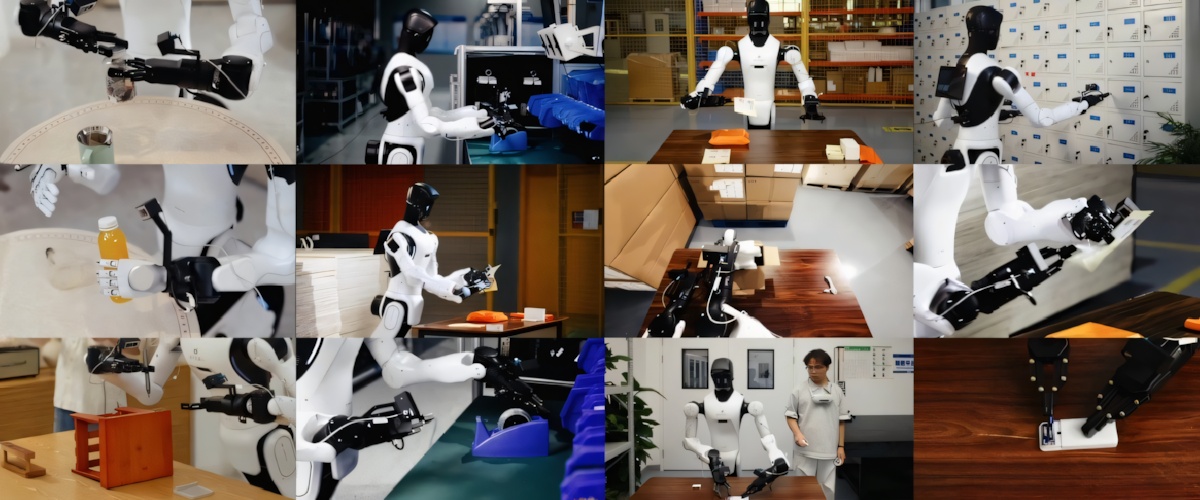
OmniPicker 3 is suitable for robotic sorting and logistics operations. The gripper can be used for moving, feeding, distributing, and stacking items as part of automated lines. The tactile sensor registers contact force, and the control system can adjust the gripper's work depending on the shape, position, and properties of the item. This is useful when working with different types of parts and products in repetitive operations. The actual performance of the system depends not only on the gripper but also on the speed of the robotic arm, movement trajectories, machine vision system, and control settings.
Application in Manufacturing Robotic Systems
- Automation of manufacturing operations. OmniPicker 3 can be installed as the end module of a robotic arm for gripping, holding, and moving parts.
- Repetitive operations. Positioning repeatability of ±0.1 mm is suitable for processes where the gripper repeatedly performs the same movements.
- Work with controlled force. The tactile sensor transmits data on contact force, allowing the adjustment of the gripper's work depending on the item.
- Sorting and moving parts. The gripper is suitable for working with items of various shapes in manufacturing and warehouse robotic systems.
- Work with delicate items. Contact force control helps adjust the grip for parts sensitive to excessive mechanical impact.
- Installation in industrial robotic complexes. Before implementation, it is necessary to separately clarify the protection class, permissible temperature range, work resource, and requirements for long-term operation.
Technical Specifications of AgiBot OmniPicker 3
| Parameter | Value |
| Maximum Force | 140 N |
| Payload | 5 kg |
| Positioning Repeatability | ±0.1 mm |
| Maximum Stroke | 110 ± 5 mm |
| Tactile Sensor | 1D |
| Force Measurement Resolution | 0.1 N |
| Interfaces | CANFD / RS485 |
| Data Collection Compatibility | UMI |
| Net Weight | 0.780 kg |
Order AgiBot OmniPicker 3
AgiBot OmniPicker 3 is suitable for enterprises, logistics centers, robotics developers, and system integrators who need a robotic gripper for sorting, moving items, automated operations, and data collection for training robotic systems. Our specialists will help select the configuration, check compatibility with the robotic platform, clarify connection options and additional cameras, agree on the configuration, and delivery conditions.